01
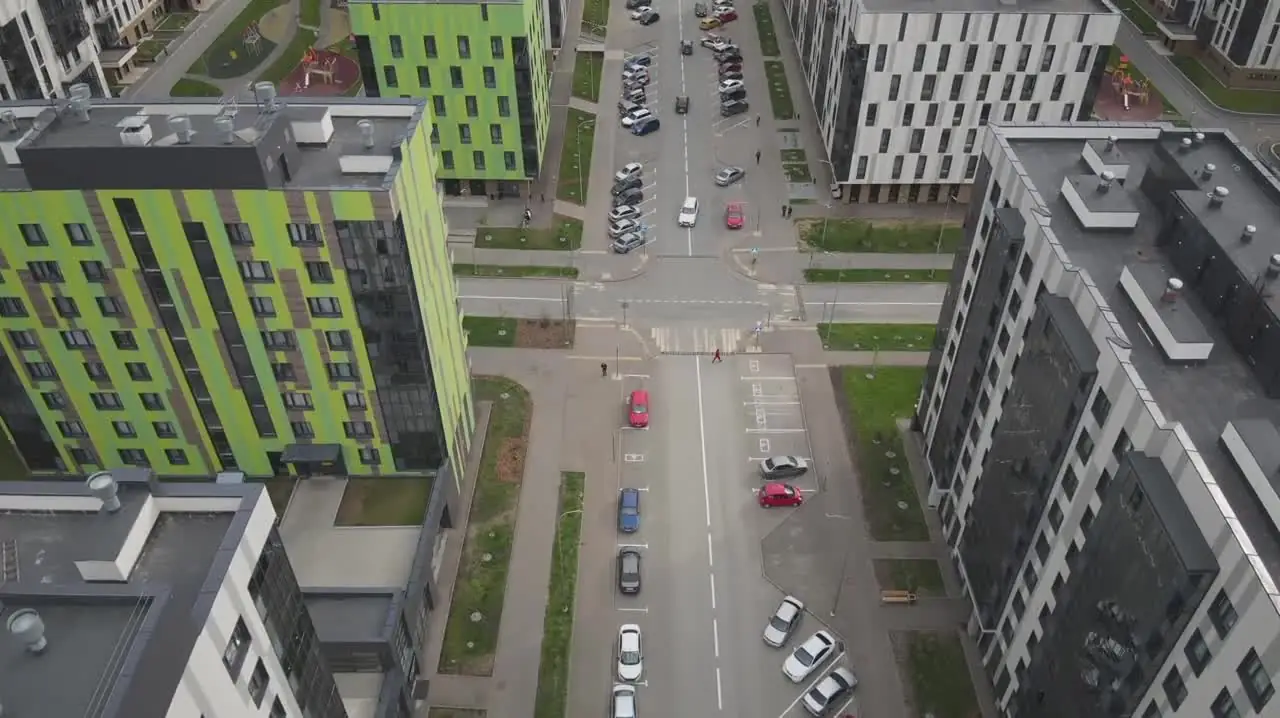
Computer Vision & Object Tracking
Object detection and multi-object tracking research using recorded-video inputs.
R&D Prototype
RAZORCLAW SYSTEMS / R&D / PRE-SEED
Building the software intelligence layer for next-generation autonomous security and aerial monitoring systems.
Computer vision, physical target tracking, reacquisition and mission-control software — developed and validated through research prototypes.
Aerial platforms add coverage, but keeping a reliable target identity, recovering after lost visibility and giving operators usable information remain hard engineering problems.
Preserving object identity through temporary loss of observation.
Turning technical data into information an operator can understand.
Bringing computer vision, events and the control interface together.
RazorClaw Systems is developing a modular platform that combines object detection, physical target tracking, reacquisition, search-state management and operator visualization.
Recorded video today. Live camera input is future work and is not claimed.
Object detection and multi-object tracking research on recorded video.
Keeps one physical target identity when individual tracker IDs change. Demonstrated in controlled tests.
Search-state logic and off-screen confidence to recover a target after lost visibility. Synthetic validation.
Mission lifecycle and event processing. Reliability testing is in progress.
Operator application for mission monitoring, target states, events and diagnostics.
Not started. Hardware integration is not shown as complete.
Five technical directions. Each status states what has actually been demonstrated.
Object detection and multi-object tracking research using recorded-video inputs.
R&D PrototypeResearch into maintaining a consistent physical target identity when individual tracker IDs change.
Demonstrated in Controlled TestsControlled test scenarios have demonstrated target reacquisition after temporary loss of visibility.
Synthetic ValidationSearch-state transitions, off-screen confidence estimation and uncertainty-aware monitoring logic.
Research PrototypeDiagnostic guidance calculations are evaluated without issuing real UAV hardware commands.
Simulation OnlyAs of October 2026. Milestones carry the status they have actually reached, with no completion percentages and no calendar promises.
A research pipeline for object detection and tracking on recorded video has been built.
Preservation of physical target identity was verified when the tracker ID changes.
A controlled scenario was run in which an object leaves the field of view and tracking is then recovered.
Successfully validated in a controlled synthetic scenario. UAV field validation is not yet complete.
An application is being developed to monitor missions, target states, events and diagnostic information.
Checks are under way on runtime lifecycle, state synchronization, WebSocket connections and event handling.
A visual reference for the new Tactical interface has been approved. Whether implementation has started is still being verified.
Technology maturity: Research & Development / Pre-Seed.
A fully integrated autonomous UAV system has not yet been validated through field trials.
Mission Monitoring, Target Intelligence & Engineering Diagnostics
A dedicated software application to visualize target lifecycle, search behavior, off-screen confidence, guidance diagnostics and mission events. It is meant to support reproducible testing, operator review and future system integration.
Demonstration overlay. Only video time and frame index are updated; tracking and guidance telemetry are not connected.
Layout of the existing engineering UI. Demo footage with a demonstration overlay; only video time and frame index are live, other fields are not populated.
Tactical is a new visual direction. Implementation status is pending verification, so it is shown as a concept only.
From detection through loss and recovery of a physical target.
Which search phase is active and why.
Uncertainty about where a lost target may be.
Guidance calculations for review only, with no hardware commands.
Entries are added by hand, and only when they can be stated accurately. Exact test results are published after the matching test report is checked.
No completion dates are committed until a resourced work plan is approved.
Shadow guidance is used for diagnostic evaluation and does not represent active UAV control.
These are requirements, not existing or validated capabilities.
Operators who monitor sites and need continuous observation.
Large sites where aerial coverage may add visibility.
Companies that could embed a tracking software layer.
Government customers — an additional segment under study.
No contracts, paid pilots, revenue or market-size figures are claimed. Confirmed calculations will be published when they exist.
Founder, RazorClaw Systems
Building RazorClaw Systems with a focus on safety, reliability and clear economics.
Technical Co-Founder / CTO — Open Role
RazorClaw Systems is seeking strategic investment and technical collaboration to move its software prototypes toward an integrated, validated aerial monitoring platform.
Research prototypes and active Control Station development.
Integrated software demonstration and broader validation.
Engineering, integration, testing and future hardware validation.
For investors, strategic partners and CTO candidates: leave your details and we will get back to you with the investor deck or a conversation about the technical role.